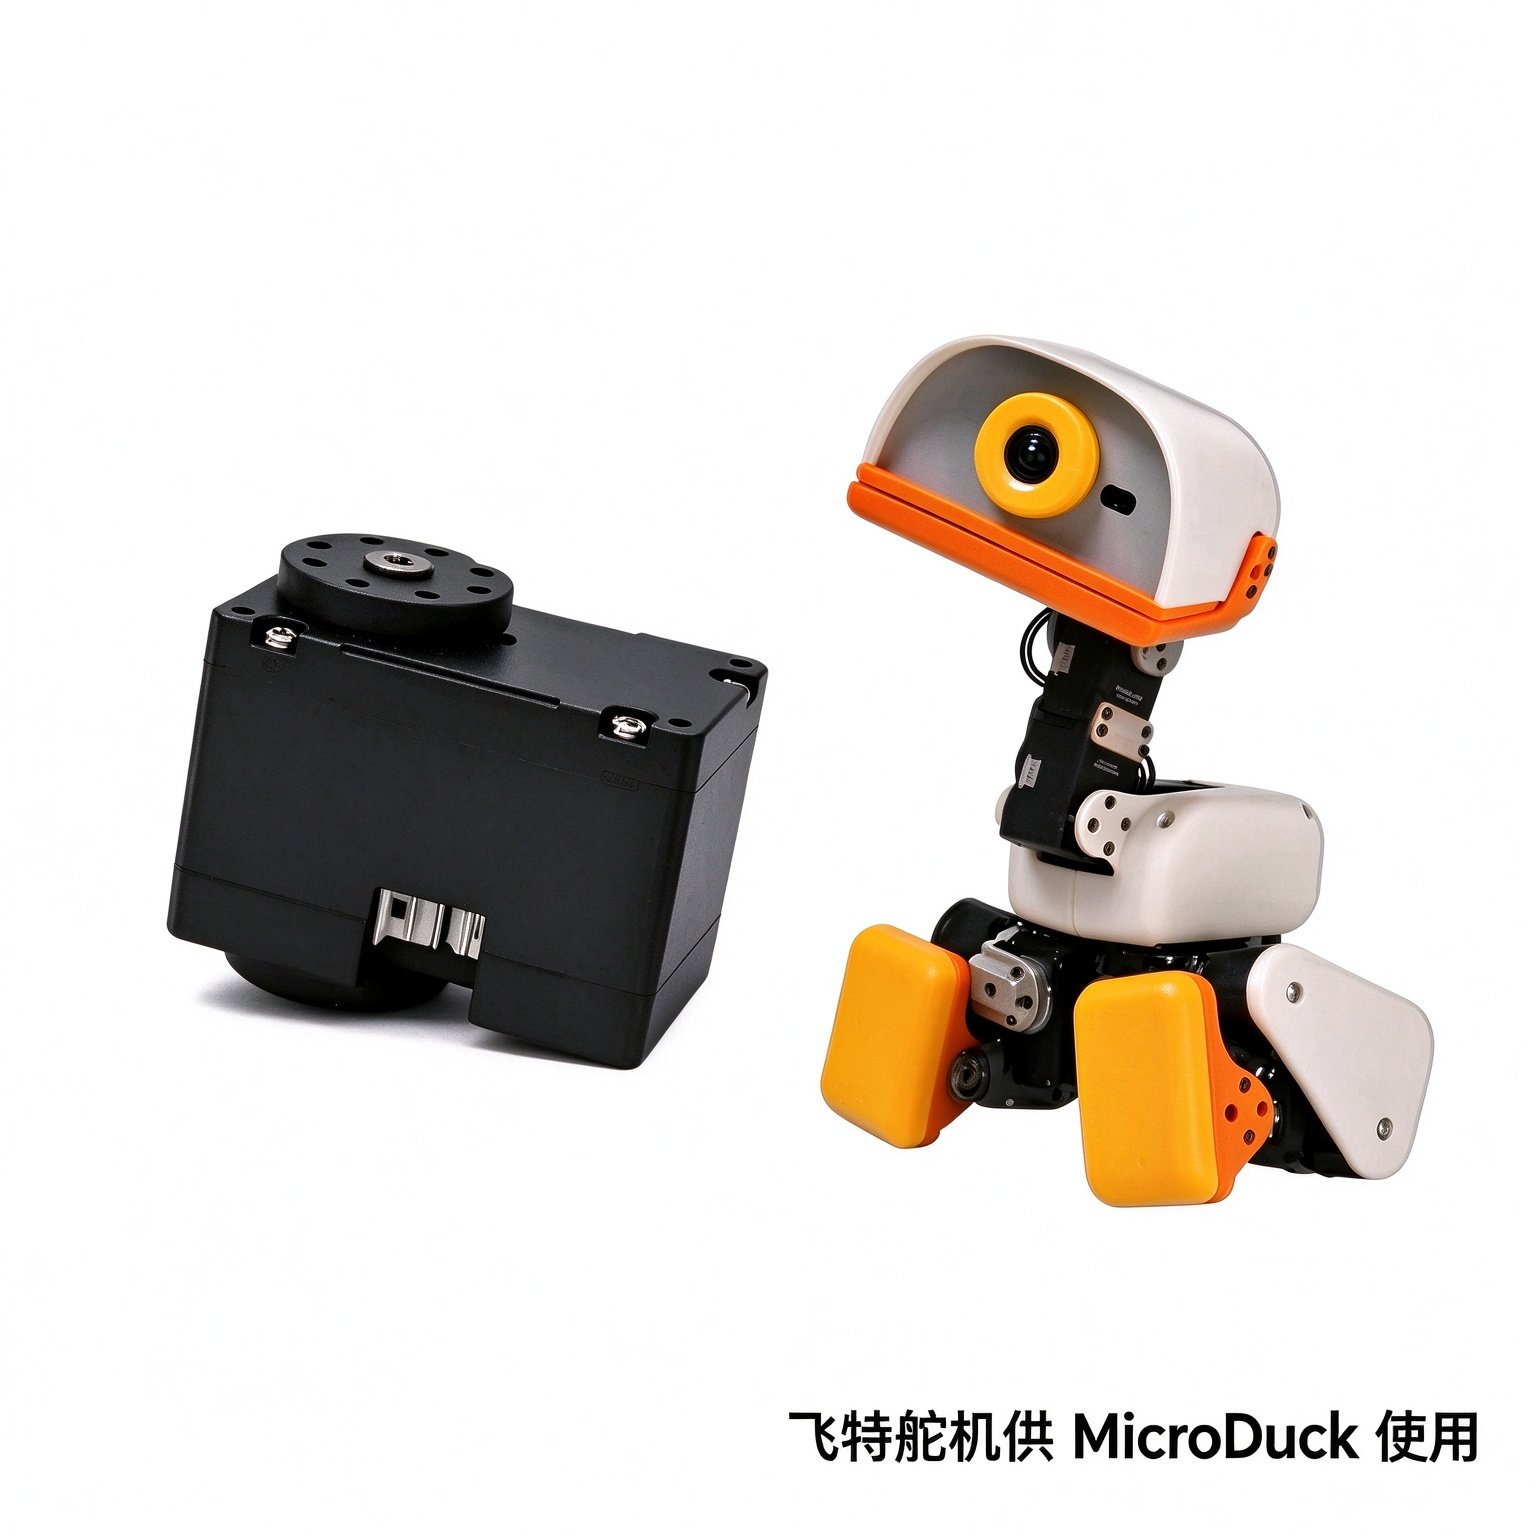
An open-source bipedal robot duck for individual developers · DIY assembly · reinforcement-learning native
A cute 25cm robot duck with 15 full-body DOF, driven by an RK3566 50Hz policy loop. Structural drawings, BOM, firmware, and the reinforcement-learning training stack are fully open-source — assemble it yourself and go from simulation to real robot, training your own embodied intelligence.
15 DOF (legs 5×2 + head/neck 4 + beak 1), 50Hz on-board policy loop, 7 built-in behaviors including walking, kicking and beak grasping, with self-recovery after falls.
Structural parts + electronics + servos + controller + battery, all included. 3D-print drawings and BOM fully open-source, with a bilingual assembly guide — build one yourself.
MuJoCo simulation + PPO training, export ONNX to deploy on the real robot. The sim-to-real toolchain is fully open, and behavior policies are retrainable.
Rust daemon architecture, Python / JavaScript scripting for custom behaviors, low-cost domestic servo alternatives — accessible even for individual developers.
| Dimensions | 25cm height · 14cm width · ~800g (≤1kg) |
| DOF | 15 DOF (legs 5×2 + head/neck 4 + beak 1) |
| Servos | 15 × domestic drop-in servos (FEETECH-compatible) |
| Controller | Rockchip RK3566 (quad-core Cortex-A55 · 0.8 TOPS NPU) |
| Memory / Storage | 1GB RAM + 32GB eMMC |
| Sensing | Wide-angle camera · 8×8 ToF depth · dual IMU · microphone · speaker · NFC |
| Connectivity | Wi-Fi · Bluetooth · NFC |
| Battery | 18650 removable battery pack, ~1 hour runtime |
| Control | 50Hz on-board policy loop · RL training via MuJoCo / PPO |
| Structure | 3D-printed (FDM / SLA) + sheet metal, fully open-source drawings |
| Built-in Behaviors | Walk · sit · crouch · kick · beak grasp · roller skate · self-recovery |
Not a toy that just loops canned motions, but an open-source bipedal robot platform you can keep experimenting with and remixing.
3D-printed structural parts, electronics, 15 servos, RK3566 controller, battery pack — all included and checked against the BOM, ready to assemble out of the box.
From printing to assembly, from flashing to first run — illustrated step-by-step tutorials. The tolerance & interference checklist is fully public, ensuring a high reproduction success rate.
Train new gaits and actions in MuJoCo with PPO, export ONNX to the real robot — teach this duck your own ideas.
Low-cost entry into reinforcement learning and embodied intelligence — train your own motion policies.
Kit assembly + open-source tutorials — take the robot apart and learn by building.
A low-cost platform for sim-to-real transfer, gait control, and domain randomization research.
A vehicle for open-source ecosystem remixing, skill-pack development, and university competitions.
A Rust 7-daemon architecture with a 50Hz motor control loop (robotd) plus safety guards; processes communicate via JSON-RPC 2.0.
MuJoCo simulation + PPO reinforcement learning with domain randomization; export ONNX to deploy on the real robot.
Hardware drawings / PCB / BOM under CERN-OHL-S, software stack and training environment under Apache-2.0, tutorials under CC BY-SA.
Get the DIY kit or a fully assembled unit, join the open-source community, and have fun with fellow developers.
Request a Consultation